Abstract
Original text · supplied manuscript
In this paper, we analyze the performance of a dual-hop mixed underwater optical wireless communication (UOWC)-multiple aperture free-space optical (FSO) relaying system by taking into account the effect of strong turbulence under pointing error (PE). To this end, we first derive a statistical channel model for the considered UOWC link alongside with the closed-form expression for its average bit error rate (BER). Then, we address the end-to-end average BER of the considered setup and we discuss the impact of PE in the UOWC link and the number of deployed receivers in the FSO link on different performance indicators. Simulation results are also included to validate the accuracy of our analysis.
ENGINEERING QUESTION
When do extra FSO receiver apertures help an underwater-to-shore relay, and when does the underwater hop become the bottleneck?
A layered underwater channel model is combined with a SIMO FSO hop to evaluate end-to-end bit error rate. Receiver diversity improves the atmospheric hop in the studied conditions, but its end-to-end benefit diminishes once underwater turbulence and pointing errors dominate.
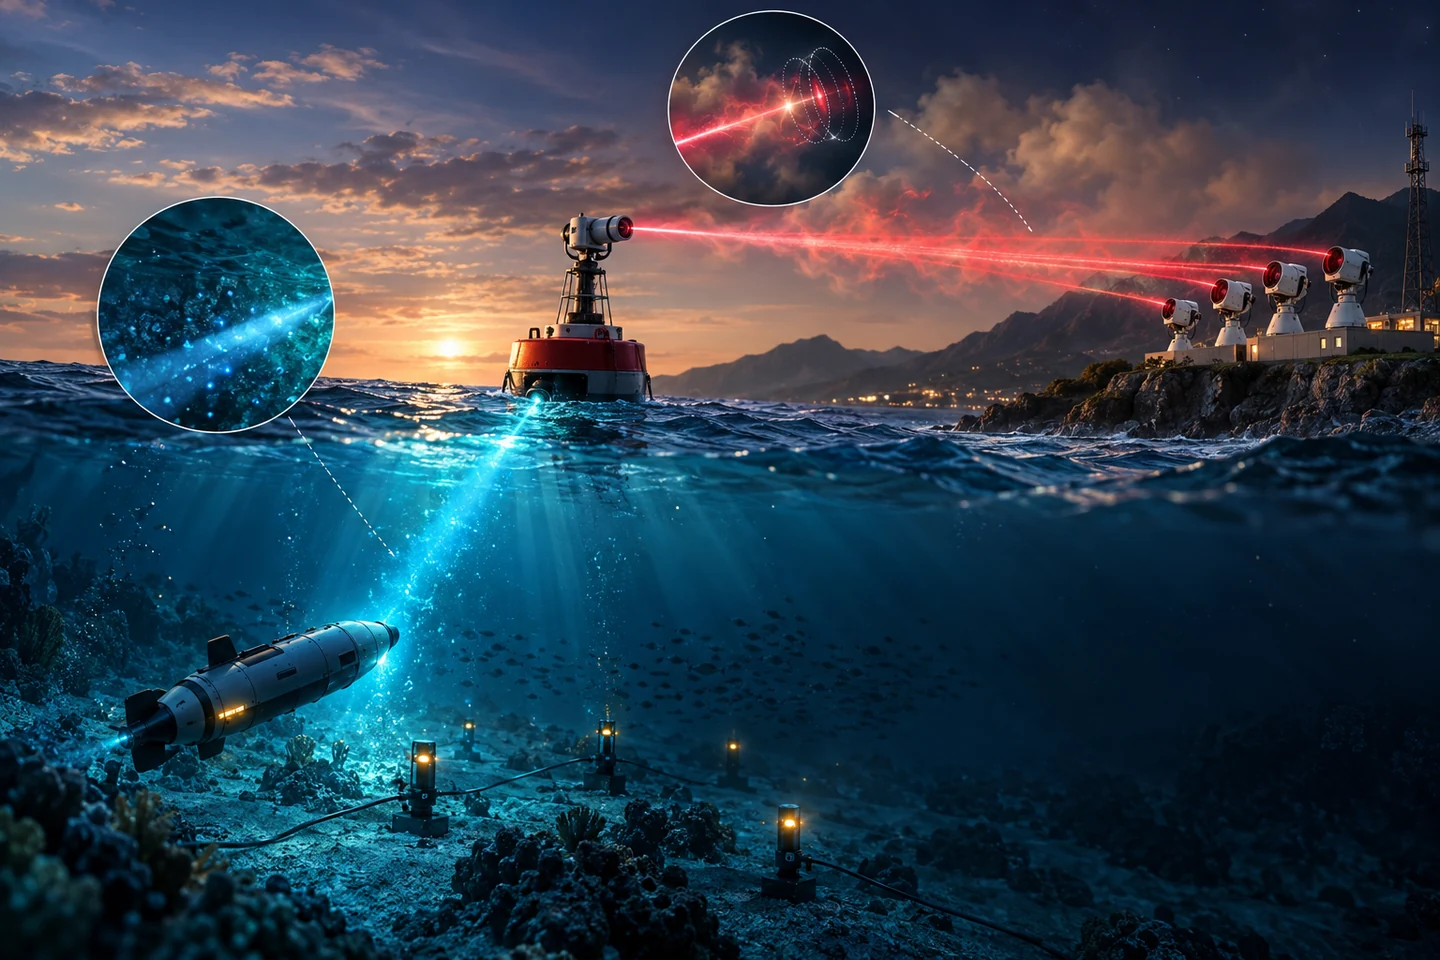
Architecture and channel assumptions
An AUV transmits to a ship-mounted decode-and-forward relay through an underwater optical link. The ship forwards the recovered signal toward multiple FSO receivers at a lighthouse or shore base station. This is receiver diversity, or SIMO, on the atmospheric hop.
The vertically stratified underwater channel is modeled as the product of independent Gamma–Gamma layer gains, with attenuation and pointing error. Gamma–Gamma turbulence and pointing loss also enter the atmospheric hop. The system uses IM/DD with M-PAM; the numerical examples use four levels.
Manuscript · Section II; Fig. 1; Table I
Method and validation
The underwater channel distribution yields a closed-form average BER involving the Meijer G-function. It is combined with an existing multiple-aperture FSO BER expression. The decode-and-forward relation is BERₑ₂ₑ = BERᵤw + BERꜰ − 2BERᵤwBERꜰ.
Analysis is checked against simulations for two and four underwater layers, several pointing-error levels, and one, two or four FSO receivers. Underwater and atmospheric wavelengths are 450 nm and 1550 nm, respectively.
Manuscript · Sections III–V; Eqs. (16), (18), (20); Table I
Results and engineering interpretation
For the atmospheric hop alone, Figure 3 reaches average BER 10⁻³ at approximately 38, 29 and 24 dB with one, two and four receivers, respectively. These values describe the FSO hop under the plotted parameters; they are not end-to-end thresholds.
In the end-to-end example, additional receivers help over roughly 0–30 dB. Above that region, the underwater hop dominates and adding atmospheric apertures delivers less improvement. Increased underwater pointing error can outweigh a favorable layer configuration.
Manuscript · Section V; Figs. 2–4
Scope and limitations
Results concern the specified statistical channels and parameter sweeps, not sea trials or a space relay. Independence between modeled water layers and the adopted pointing model are simplifying assumptions. Extra shore receivers add hardware; diversity cannot compensate indefinitely for an impaired underwater hop.
Manuscript · Sections II–VI
Publication record
- Authors
- Mahdis Saghaee Jahed, Meysam Ghanbari, Seyed Mohammad Sajad Sadough
- Venue
- 2023 31st International Conference on Electrical Engineering (ICEE)
- Location
- Tehran, Iran
- Status
- Published
- Year
- 2023
- Publication date
- 2023-05-09
- Pages
- 512-516
- DOI
- 10.1109/ICEE59167.2023.10334840
The original abstract and technical explanation follow the supplied manuscript. Bibliographic details are checked against the publisher’s Crossref record. The technical explanation is editorial and separate from the original abstract. Research note updated 2026-10-03.